


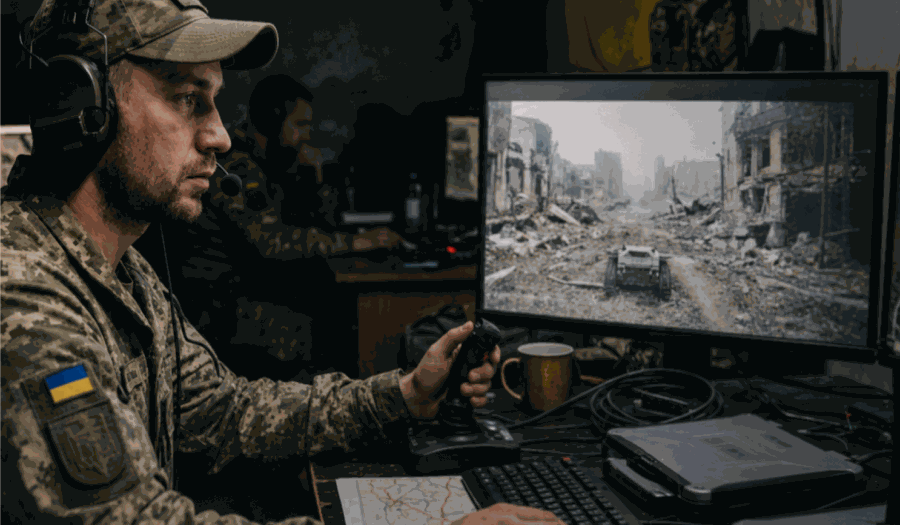
Modern combat operations increasingly take place without the direct presence of a person in a dangerous zone. Ground robotic platforms take on the tasks of reconnaissance, delivery, or working in conditions where the risk is too high. But their effectiveness directly depends on how stably they can be controlled at a distance.
In practice, the main difficulty lies not in the equipment itself but in signal transmission. Any communication channel is subject to the influence of terrain, buildings, or obstacles. Even a small delay or a brief loss of signal immediately affects control.
The Principle of Remote Control of Robotic Platforms
Remote control is a constant exchange of data between the operator and the platform. Commands to move, stop, or perform tasks are transmitted forward, and video and telemetry are returned back. The whole system works as a closed loop, where each action depends on the speed of the response.
If the signal passes with a delay, control becomes less precise. Already at 1-2 seconds of delay the operator begins to react with a lag, and at a larger value an effect of ‘inertial control’ arises, when the platform moves faster than the operator can correct it.
In open terrain this effect is less noticeable, but in urban conditions or among obstacles it becomes critical. That is why remote control is always built taking delays into account rather than ideal conditions.
The Data Transmission Channel for Controlling Ground Robots
The data transmission channel is the key element through which all control passes. It is what determines whether the platform will be obedient or become uncontrollable at a critical moment.
In most cases the 2.4 or 5.8 GHz bands are used. The first provides better range, the second faster data transmission. In open terrain a stable link can reach several kilometers, but in real conditions these values are often reduced.
For example, in a city the signal can be lost already after 300–500 meters due to buildings and obstacles. In the field it is affected by terrain — hills, forest, or equipment. That is why the channel is considered a dynamic part of the system that constantly changes under the influence of the environment.
Video Transmission and Telemetry During Remote Control
For effective control, the operator needs not only a command but an understanding of the situation. Video shows the environment, and telemetry gives precise parameters of the platform’s operation — speed, position, signal level, and the state of the systems.
These two data streams work simultaneously but at different speeds. Telemetry is usually transmitted faster so that control remains stable even with video delays. It is what allows the operator to make decisions even if the picture lags slightly.
In practice the operator often relies more on telemetry than on video in difficult conditions. If the channel is overloaded, the system can reduce video quality but keep the control signals stable.
Ground Robotic Platforms in Combat Conditions
Ground robots are used where the risk to a person is too high. This can be reconnaissance, ammunition delivery, or working in a zone of fire. In such conditions, what matters is not only the platform’s functionality but also the stability of its control.
A typical situation looks like this: the platform moves along a route, transmits video, the operator corrects its movement in the process. If the link is unstable, each action requires more time, and the risk of error grows.
In this context, the «Bandura» tactical ground drone is used. It is a separate robotic platform that combines the control channel, video transmission, and telemetry in a single system. It makes it possible for the operator to get the full picture and maintain control even in difficult communication conditions, which is critical in real use.
Protecting Control Channels From Interference and Interception
The control channel is always at risk of being affected. It can be the target of jamming, overloading, or interception, especially in conditions of active electronic warfare.
Various methods are used for protection: frequency hopping, signal encryption, transmission in short packets, and the use of backup channels. The best result comes from a combination of these approaches.
Even with protection in place, the channel does not become completely invulnerable. The system’s task is to maintain control long enough for the operator to complete the task or bring the platform out of the dangerous zone.
To better understand how these solutions are applied in practice, see the article: «Ground robots in war: the future of military robotics», which covers real-world equipment scenarios.
Limitations of Remote Control of Robotic Platforms
Despite the development of technology, remote control has limitations that cannot be completely eliminated. The first is dependence on the communication channel. If it is lost, the platform either switches to a limited mode or completely loses control.
The second factor is signal delay. Even 1-2 seconds can significantly affect maneuvering accuracy, especially in difficult conditions or when operating at speed.
Environmental conditions also matter. Terrain, buildings, and weather factors change the behavior of the signal and affect the stability of control. As a result, the effectiveness of the system always depends on the balance between technology and real conditions.
Conclusions
Remote-control technologies for robotic platforms make it possible to carry out tasks without the direct presence of a person in a dangerous zone. They are based on a stable data transmission channel, video and telemetry transmission, and proper organization of control.
The effectiveness of such systems is determined by how well transmission speed, link resilience, and the ability to work in conditions of interference are combined.